Omron TM robots ROS — palletizing and gripper applications
by Community Import
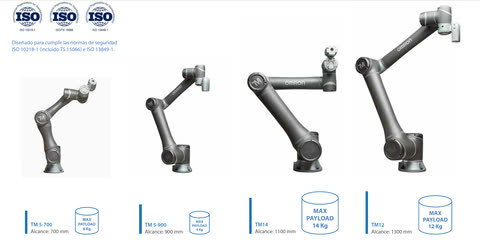
Forked from TechmanRobot tmr_ros1. Developed and tested using the TM5-700, TM5-900 and TM12-1300 with TMFlow 1.84.2200. tm5_700_gripper_moveit_config works with TM5-700 and a Robotiq_85 gripper; tm12_palletizer_moveit_config works with TM12-1300 and a Schmalz vacuum gripper, both using MoveIt Python API and Gazebo.
— Imported from https://github.com/GiakNab/Omron_TM_robots-ROS (author: GiakNab)
| Required hardware / BOM | TM5-700 with Robotiq_85 gripper; TM12-1300 with Schmalz vacuum gripper |
|---|---|
| Task | Palletizing |
| Robot | Techman TM12-1300 |
| Licence | other |
⚠️ Safety notes
⚠️ Imported from a third-party source and NOT tested by cobotmove or the importer. These instructions move a real industrial robot. Review the full program, verify reach/payload/TCP for your exact cell, and run in simulation with E-stops verified before any live motion. Used entirely at your own risk. Original source: https://github.com/GiakNab/Omron_TM_robots-ROS