Kuka KR210 Pick and Place Project
by Community Import
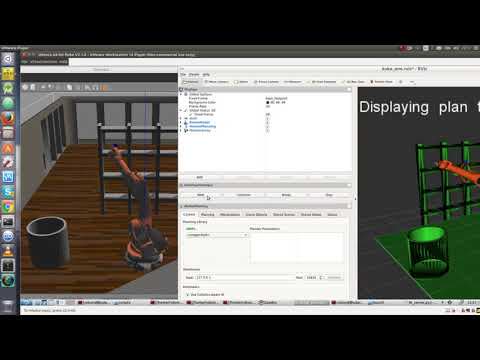
Programming the rotation and translation matrices for a Kuka KR210 6-DOF arm to perform a basic pick and place operation in the Gazebo robot simulator. Uses inverse kinematics (IK_server.py) to calculate joint angles to pick a cylinder from a shelf and drop it in a bin.
— Imported from https://github.com/PatrickMockridge/Udacity-Kuka-Arm-Pick-And-Place (author: PatrickMockridge)
| Task | Pick & place |
|---|---|
| Robot | KUKA KR210 |
| Licence | other |
⚠️ Safety notes
⚠️ Imported from a third-party source and NOT tested by cobotmove or the importer. These instructions move a real industrial robot. Review the full program, verify reach/payload/TCP for your exact cell, and run in simulation with E-stops verified before any live motion. Used entirely at your own risk. Original source: https://github.com/PatrickMockridge/Udacity-Kuka-Arm-Pick-And-Place