Fanuc_KAREL_hello_world
by Community Import
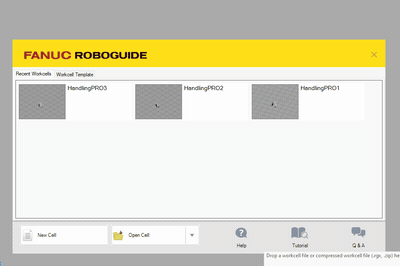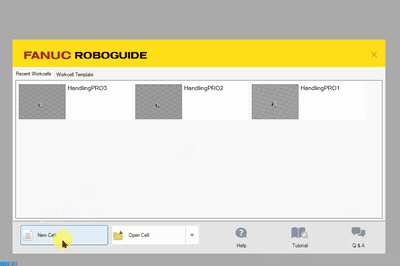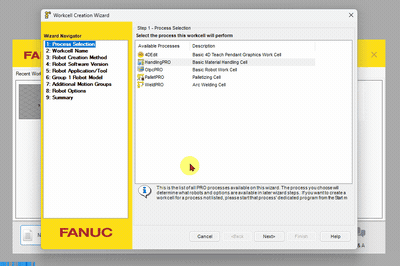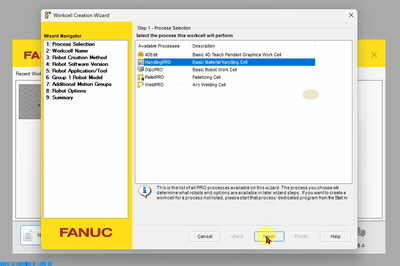
Instructions for using Fanuc's KAREL programming language to create / run a simple hello world program. This demo was created using Fanuc's ROBOGUIDE simulator running their CRX-20iA/L controller.
— Imported from https://gist.github.com/Shawn-Armstrong/6523676f1cf25e6373c2f27e487e86ad (author: Shawn-Armstrong)
| Task | Other |
|---|---|
| Robot | FANUC CRX-20iA/L |
| Licence | other |
⚠️ Safety notes
⚠️ Imported from a third-party source and NOT tested by cobotmove or the importer. These instructions move a real industrial robot. Review the full program, verify reach/payload/TCP for your exact cell, and run in simulation with E-stops verified before any live motion. Used entirely at your own risk. Original source: https://gist.github.com/Shawn-Armstrong/6523676f1cf25e6373c2f27e487e86ad