cup-stacking-force-control
by Community Import
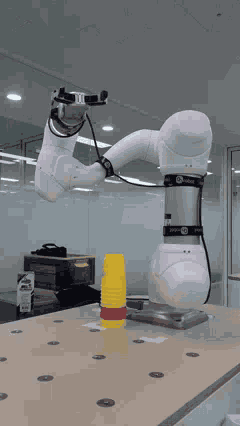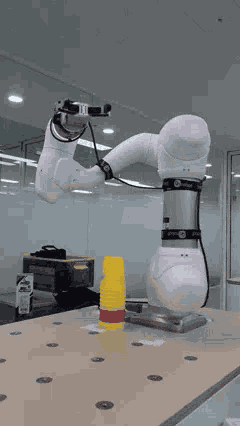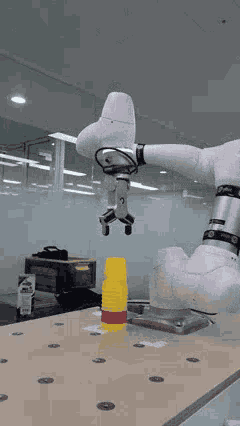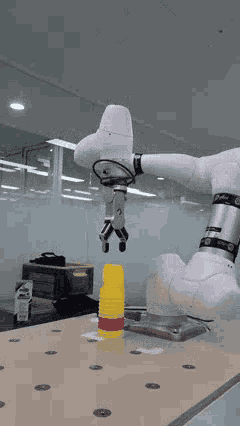
A portfolio project demonstrating a force-controlled cup stacking task using a Doosan collaborative robot. Showcases precise manipulation through force feedback, with Python-based control logic (force_control.py), presentation slides, and a demonstration video.
— Imported from https://github.com/Chos0823/cup-stacking-force-control (author: Chos0823)
| Task | Pick & place |
|---|---|
| Robot | Doosan |
| Licence | MIT |
⚠️ Safety notes
⚠️ Imported from a third-party source and NOT tested by cobotmove or the importer. These instructions move a real industrial robot. Review the full program, verify reach/payload/TCP for your exact cell, and run in simulation with E-stops verified before any live motion. Used entirely at your own risk. Original source: https://github.com/Chos0823/cup-stacking-force-control